Tutorial Videos
This page indexes the MRMC / Flair YouTube tutorial playlists referenced by the knowledgebase. Each entry includes the source video, thumbnail, detailed AI summary, topic tags, and available chapter headings.
Playlists
- MRMC Academy - Motion Control Concepts — 17 videos
- Flair 7 Quick Tips and Tutorials — 12 videos
- Flair Training Videos — 29 videos
- Simul8 Tutorials — 10 videos
- Flair 7 Training Videos — 35 videos
- Flair Lite & Nano Tutorials — 8 videos
- Cinebot Mini/Max & Flair 7 Training — 46 videos
Community Videos
Videos hosted directly rather than via YouTube, from sources such as the community forum.
- Community Forum Videos — Videos originally posted natively to the talk.mrmoco.com forum (not YouTube) — recovered and hosted directly, with full transcripts.
MRMC Academy - Motion Control Concepts
Short explainers covering motion control concepts, virtual production, scaling, repeat passes, PushMoco, target tracking, and rig selection.
1. What Is Motion Control?

AI Summary
Have you ever caught yourself asking, "What is motion control?" Well, ask no more! In the first episode of our new series, "MRMC Academy," our host @itsbenreel aims to answer all your burning questions and give you a breakdown of what exactly moco is and how it is used in the industry to create some awesome effects in film and commercial work.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, Phantom workflows, import/export, and move programming, while it also touches on synchronization and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT and CAMERA_PHANTOM. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
2. The Evolution of Motion Control With MRMC

AI Summary
Dive into this exciting journey through the rich history of MRMC and discover how our motion control robotics have evolved from the early days to the cutting-edge technology we use today.
For operators using this as a reference, the main focus is firmware flashing, move programming, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, BOLT_X, and CINEBOT_MINI. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
3. Which Rig Is Right For You?

AI Summary
In this episode, your host Ben explores the unique features of each leading MRMC motion control rig, offering insights into how each one might fit your setup. He even provides live demonstrations, showcasing how his own Cinebot Mini operates and how it can create impressive effects in confined spaces.
For operators using this as a reference, the main focus is HHB, Phantom workflows, mimic systems, and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, BOLT_JR, BOLT_X, CINEBOT_MINI, HHB, and MIMIC. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
4. Flair: The Industry Leading Motion Control Software

AI Summary
In this exciting episode of MRMC academy, we're diving into the details of Flair — the industry-leading software used by motion control professionals worldwide.
For operators using this as a reference, the main focus is CGI matching, import/export, move programming, robot safety, and target tracking, while it also touches on track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
5. Why Get The Cinebot Mini?

AI Summary
Enjoy this very special episode of MRMC Academy—a passion project from Ben himself, where he shares exactly why he loves using the Cinebot Mini.
For operators using this as a reference, the main focus is move programming and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, BOLT_JR, CINEBOT_MINI, and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
6. Transporting Your Cinebot Mini

AI Summary
Following Ben’s glowing recommendation in the previous episode, in this installment of MRMC Academy, he demonstrates just how quick and easy it is to pack up the Cinebot Mini and wheel it onto set.
For operators using this as a reference, the main focus is mimic systems and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
7. Creating Precision Paths With Motion Control

AI Summary
Today, we’re diving into precision paths — how cameras and robotic systems move along a specific trajectory with pinpoint accuracy to pull off incredible shots.
For operators using this as a reference, the main focus is motion smoothing, move programming, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 2 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
8. What is a Repeat Pass?

AI Summary
Ever wonder how movies clone characters to share the screen with their real-life counterparts, or how commercials make products appear and disappear seamlessly—even during dynamic camera moves? It’s all thanks to motion control and a game-changing technique called the repeat-pass.
For operators using this as a reference, the main focus is CGI matching, move programming, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
9. What Is Target Tracking?

AI Summary
This week, we’re diving into Target Tracking!
For operators using this as a reference, the main focus is CGI matching, move programming, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
10. Triggering and Timing In Motion Control

AI Summary
In this episode of MRMC Academy, your host, @itsbenreel explores how synchronised triggers and components work with Flair motion control to execute perfectly timed shots.
For operators using this as a reference, the main focus is CGI matching, import/export, move programming, synchronization, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
11. What Is PushMoco?

AI Summary
Ever struggle to explain exactly how you want a shot to move? When working with camera robots, translating your vision into precise motion can sometimes be tricky, but that’s where PushMoco comes in.
For operators using this as a reference, the main focus is HHB, mimic systems, motion smoothing, move programming, and robot safety, while it also touches on target tracking and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, CINEBOT_MINI, HHB, MIMIC, and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:54 — tool that allows creative collaborators to physically move the camera into
- 02:39 — push Moko mode the robot's trying to work with you to move the camera and so
- 03:43 — Moco mode they will turn green push Moko does work with the track as well if you
- 04:51 — line we will move the robot to another
- 05:50 — subject point and just like that we have a three-point move let's see what it
- 08:14 — shoot and just like that we have a move
12. How to Create Slow Motion Shots with Motion Control

AI Summary
Dive into the fascinating world of high-speed motion control and see how you can bring dynamic slow-motion effects to life.
For operators using this as a reference, the main focus is move programming, pre/post-roll, target tracking, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
13. How Motion Control Powers Virtual Production

AI Summary
In this virtual production special, Ben dives into how motion control integrates with virtual production — specifically ICVFX, and how to film CGI and practical elements simultaneously to create ultra-realistic camera effects.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, import/export, move programming, and target tracking, while it also touches on zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:17 — talking about integrating motion control with virtual production and more
- 01:02 — backgrounds onto. ICV effect studios use tracking systems to pinpoint the real
- 01:48 — Uh, this is what happens with the majority of tracking solutions. But once
- 02:33 — to be pretty good for this system. We'll back on the move. And as you can
14. What Is Scaling In Motion Control?

AI Summary
This time around, @itsbenreel unpacks how you can use scaling to recreate the exact same camera move across different-sized subjects, or environments without rebuilding your move from scratch.
For operators using this as a reference, the main focus is CGI matching, EtherCAT, Maya workflows, import/export, and move programming, while it also touches on target tracking, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:40 — you alter the size, position, or rotation of a camera move to create some
- 01:27 — move slower in real life. And the second
- 02:20 — camera to the right height and orientation that I want the move to
- 03:13 — way your edges are nice and clean. Being able to run the move in cartisian
- 04:12 — of final tips I'll leave you with. Uh, make sure that your focal lengths match
15. Scaling With Motion Control Part 2

AI Summary
It’s Time to Scale Things Up (Again)!
For operators using this as a reference, the main focus is Maya workflows, import/export, motion smoothing, move programming, and target tracking, while it also touches on track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
16. The Importance Of Previsualization

AI Summary
Previs is all about planning your move before the camera ever rolls, helping you test ideas, refine timing, and walk onto set with confidence. It is a powerful part of the motion control workflow, but how does it actually work in practice?
For operators using this as a reference, the main focus is CGI matching, import/export, motion smoothing, and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
17. What Is Cartesian Control?

AI Summary
We’re diving into Cartesian Controls. It might sound complex, but it’s more straightforward than you think.
For operators using this as a reference, the main focus is move programming, target tracking, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:41 — tells the robot where it needs to be. And when we use target tracking modes,
- 01:27 — use this to our advantage by placing the track in a strategic position in
- 02:58 — facing. Carts view is the secret sauce that allows us to move in a nice arc
- 04:00 — and locked roll. We can use carts roll or locked roll to move in a way that
- 05:24 — modes to pilot the camera with precision to find the rest of the move. I found
Flair 7 Quick Tips and Tutorials
Short Flair 7 workflow videos for importing moves, triggers, Graph View, keyboard shortcuts, focus calibration, Live View, exporting, HHB setup, and the Tracker App.
1. Flair 7 Quick Tips: Move Import

AI Summary
In this Flair 7 Quick Tips tutorial Matt shows you the Move Import feature.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, import/export, mimic systems, and move programming, while it also touches on target tracking and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes MIMIC, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
2. Flair 7 Quick Tips: Output Triggers

AI Summary
In this Flair 7 Quick Tips tutorial Matt shows you the set-up of output triggers.
For operators using this as a reference, the main focus is move programming, pre/post-roll, and synchronization. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes TRIGGER_BOX, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
3. Flair 7 Quick Tips: Graph View

AI Summary
In this Flair 7 Quick Tips tutorial Matt shows you the dynamic features of the graph view.
For operators using this as a reference, the main focus is axis limits, motion smoothing, move programming, pre/post-roll, and robot safety, while it also touches on spline behaviour, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
4. Flair 7 Quick Tips: Keyboard Shortcuts

AI Summary
For the next few weeks, every Friday we'll be bringing you a new tutorial to help you make the most of our premier motion control software, Flair 7.
For operators using this as a reference, the main focus is track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
5. Flair 7 Quick Tips: Focus Calibration

AI Summary
In our latest Flair 7 quick tips tutorial, Matt takes you through how to calibrate the focus of your selected lens, allowing you to create a move and have the focus automatically pull to the target point!
For operators using this as a reference, the main focus is lens calibration, move programming, robot safety, spline behaviour, and target tracking, while it also touches on zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
6. Flair 7 Quick Tips: Live View Setup

AI Summary
This week Matt takes you through how to set up and use the Live View, and how the cartesian control buttons act as a visual guide to help you control the camera in 3D space, simplifying the tracking capabilities of Flair!
For operators using this as a reference, the main focus is move programming, robot safety, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
7. Flair 7 Quick Tips: Exporting a Move

AI Summary
In this week's Flair 7 Quick Tip Matt takes you through how to export a move from Flair in a variety of formats!
For operators using this as a reference, the main focus is CGI matching, EtherCAT, Maya workflows, import/export, and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
8. Flair 7 Tutorial: Creating a 3 Point Move by Rite
AI Summary
Rite talks us through creating a 3 point move in Flair 7.
For operators using this as a reference, the main focus is motion smoothing, move programming, spline behaviour, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:07 — today we're going to learn how to do a three-point move in flare 7.
- 01:31 — we go we can move using our carts and still be
- 02:49 — position one now if we look at our robot move up here it's just going in a
- 03:51 — we know that this is the peak of the move so maybe you want to tilt down a
- 04:42 — 88.1 because you're uh let's see your acceleration
- 06:23 — pretty close if we wanted to we could massage this move
9. Flair 7 Tutorial: Using Triggers by Rite

AI Summary
Rite talks us through using Triggers in Flair 7.
For operators using this as a reference, the main focus is move programming and synchronization. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7 and flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 2 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
10. Flair 7 Quick Tips: Hand-held Box Configuration

AI Summary
In this Flair 7 Quick Tips tutorial Matt shows you the hand-held box setup and how to configure your USB controller for operating with Flair 7.
For operators using this as a reference, the main focus is HHB and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 2 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
11. Flair 7 Quick Tips: Customising the Main Window

AI Summary
Learn how to customise your main window layout and personalise your Flair experience.
For operators using this as a reference, the main focus is hot booting and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
12. MRMC Tracker App Features Reel

AI Summary
The MRMC Tracker App is your gateway to precision motion control filmmaking. The App empowers directors to capture and convey their vision effortlessly, using just an iPhone or iPad to frame and navigate a motion control shot.
For operators using this as a reference, the main focus is target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 1 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
Flair Training Videos
Longer Flair Classic training videos covering the core operator workflow: moves, curves, target tracking, lens calibration, cartesian control, triggers, sync, importing/exporting, axis setup, rig models, and FBX workflows.
1. Intro to flair Part 1

AI Summary
Get familiar with the Flair interface. Learn how to control the axes of a robot, how to store waypoints to create a move and then how to run your move.
For operators using this as a reference, the main focus is motion smoothing, move programming, robot safety, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT and CAMERA_RED, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
2. Intro to flair Part 2

AI Summary
Learn about curves, speed ramping, pre- and post-roll to achieve the exact look of the motion in your footage you want.
For operators using this as a reference, the main focus is pre/post-roll. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 1 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
3. Curve Adjustment

AI Summary
Look into advanced curve adjustments and focus pulling on multipoint moves.
For operators using this as a reference, the main focus is move programming and spline behaviour. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 10 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:06 — [Music] we're now going to show some curve
- 00:56 — is changing direction not on the Waypoint the spline curve that defined
- 01:45 — fresh middle Mouse it changes the curve
- 02:35 — the Waypoint thus you have two entirely
- 03:33 — tilt to change direction twice if I now calculate that move and look at my
- 04:52 — wish go to a different frame somewhere along that move and slightly change
- 05:37 — moving the camera individually if I were to run that move shoot it waves around
- 06:24 — opportunity now arises having made that move and given it a name
- 07:46 — because other axes were not moving when I need the go to it didn't move to that
- 08:36 — want to focus on rather than not being in focus throughout the move I can add
4. Target Tracking Part 1

AI Summary
Understand the basics of target tracking to keep your subject in frame while moving the robot around it.
For operators using this as a reference, the main focus is move programming and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:30 — something whereby we introduced something called target tracking I'm
- 03:23 — there I have a to position move I'm
- 04:16 — and treat it as you can see from the move although we start looking at the
- 05:01 — going to use something called target tracking I'm going to go to the start of
- 07:03 — and I turn on something called target tracking tracking on and I also make my
- 07:51 — camera looks at the bottle precisely throughout the move this is called
- 08:38 — will be what I am looking at when I do my move this relies on my machine
- 09:30 — correct then I will be able to do accurate target tracking because flare
5. Target Tracking Part 2

AI Summary
Dive deep into more advanced target tracking and learn how to keep your subject in focus throughout the whole move.
For operators using this as a reference, the main focus is move programming, spline behaviour, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
6. Lens Calibration Part 1

AI Summary
Learn how to setup, scale and calibrate the focus axis of a lens in Flair.
For operators using this as a reference, the main focus is axis limits, lens calibration, motion smoothing, move programming, and robot safety, while it also touches on spline behaviour, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
7. Lens Calibration Part 2

AI Summary
Understand the relation between the lens and the robot, and learn how to measure the nodal point of the lens.
For operators using this as a reference, the main focus is lens calibration and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
8. Cartesian Control

AI Summary
Learn how to move the robot in 3D space by X-Y-Z axes instead of direct (joint) axes to easily and quickly manoeuvre to your desired framing.
For operators using this as a reference, the main focus is move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 1 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
9. TT and cart theory

AI Summary
Get a better understanding of cartesian control and it’s relation to target tracking.
For operators using this as a reference, the main focus is move programming and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 9 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:11 — we need to put some theory to understand why target tracking in Cartesian
- 00:58 — my machine so I need a large axis but move my camera in X Y and instead
- 01:57 — thus in order for target tracking to
- 02:43 — to be able to move my camera in 3d space
- 03:32 — defines which axes our target tracking
- 04:30 — therefore I have three large axes that move my camera and define where in space
- 05:17 — camera the target is moving in space so pan as a target tracking axis is obeying
- 06:04 — camera therefore I can move my camera in
- 06:50 — tracking actually he's free to do
10. Triggers Box and bloop
AI Summary
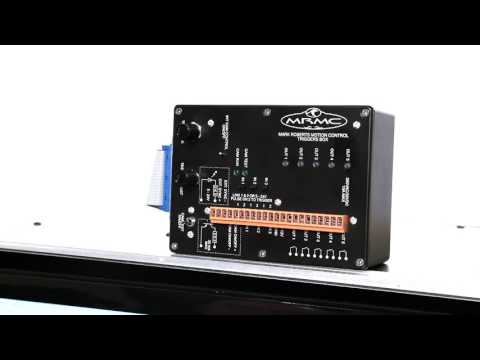
Learn how to sync external devices and events to the movement of the robot and the footage.
For operators using this as a reference, the main focus is CGI matching, firmware flashing, move programming, pre/post-roll, and synchronization. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BLOOP_LIGHT and TRIGGER_BOX, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
11. Camera Triggering and Synchronisation

AI Summary
Learn how to synchronise Flair and the robot to the camera and how to trigger it.
For operators using this as a reference, the main focus is EtherCAT, Phantom workflows, move programming, pre/post-roll, and robot safety, while it also touches on synchronization and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT and CAMERA_PHANTOM, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
12. Example Move Program

AI Summary
Go through the process of creating a move.
For operators using this as a reference, the main focus is move programming, robot safety, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
13. Browsing and GoTo

AI Summary
What care they need to take when doing Gotos, and a method for overcoming it, and a very useful system for checking a move.
For operators using this as a reference, the main focus is HHB, move programming, and robot safety. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
14. Tracks, Master axes and Cartesians

AI Summary
The addition of track and the advantages brought by this and the use of master axes.
For operators using this as a reference, the main focus is move programming, target tracking, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:13 — having three large Exige you used to move the camera in X Y Z and three small
- 01:09 — to be able to decide which of those target tracking axes are not going to be
- 01:57 — four possible target tracking axes to
- 02:52 — place the whole machine in order to do accurate target tracking the object of
- 03:56 — have my arm stays black because it is a master axis my track is actually x-axis
- 04:45 — order to have that type of job but then if I am in Cartesian view and I move the
- 05:32 — my arm is a target tracking axis so now
- 06:19 — these axes here the track is a master
15. Zeros and Limits

AI Summary
Setting up zero positions for the machine and the use of limits.
For operators using this as a reference, the main focus is CGI matching, axis limits, mimic systems, motion smoothing, and robot safety, while it also touches on target tracking, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 10 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:22 — necessary and we want to know a reference point about which that file
- 01:07 — and those motors can go to the home zero
- 01:53 — engage the motor and we directly zero
- 02:42 — axis each morning when we turn on the machine needs to go and find its zero
- 03:28 — checked the magnetic edge against a single line on the track encoder this
- 04:26 — there's the magnet counting zero marker
- 05:16 — distance to my hardware limits I have to have Hardware limits on the track that
- 06:02 — at 403 centimeters forward of my datum
- 06:48 — I am trying to make it go run forward it stops on the software limit which I have
- 07:34 — the only reason I need to find home for
16. Exporting Moves

AI Summary
Introduction to exporting moves into Maya and other CG platforms.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, import/export, and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
17. Importing Moves

AI Summary
Introduction to sequences for importing other previs and moves.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, import/export, motion smoothing, and move programming, while it also touches on robot safety, target tracking, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 10 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:28 — run on your machine so you need to take his pre-visualization and import it into
- 01:21 — view this on our rig model to see what the move is
- 02:07 — to import it again and I'm going to set
- 02:52 — reaching it one of the things I can do is I can move my master axis in order to
- 03:41 — importing every tenth frame which will enable me to better maneuver the job
- 04:31 — three meters in X so it is in the center of my rail I'm also going to bring it
- 05:35 — therefore I'm going to import again at
- 06:21 — have been provisioned iced by a client in a virtual world you can stop dead
- 07:07 — rotated the move to fit better on the
- 08:23 — that works fine if it's on my rail I
18. Flair Axis Setup

AI Summary
How to set up a new Axis or Turntable in Flair.
For operators using this as a reference, the main focus is EtherCAT, HHB, Maya workflows, axis limits, and import/export, while it also touches on mimic systems, motion smoothing, move programming, robot safety, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, CAMERA_RED, HHB, PRECISION_TRACK, ROOTBOX, and TURNTABLE, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 23 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:00 — Intro
- 02:12 — The Axis
- 03:17 — Internal Scale
- 03:43 — Independent Axis
- 04:08 — Tuning
- 05:00 — Control
- 05:43 — Turntable
- 05:59 — Speed
- 07:08 — Scale
- 09:28 — Calculate Scale
- 12:07 — Scale Axis
- 13:27 — Speed Test
- 14:48 — No Mode
- 15:58 — Acceleration
- 17:10 — Goto Velocity
- 18:05 — Turntable Limit
- 19:06 — Zeroing
- 20:47 — Zero
- 20:54 — Zero Offset
- 22:39 — Zero Speed
- 22:50 — Handheld Boss Velocity
- 23:24 — Right Click Setup
- 24:18 — Save as
19. Milo Introduction

AI Summary
An Introduction to the Top Motion Control Rig available worldwide.
For operators using this as a reference, the main focus is CGI matching, import/export, motion smoothing, move programming, and target tracking, while it also touches on track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT and PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
20. Scaling on a Milo

AI Summary
How to do that precision Scaling shot.
For operators using this as a reference, the main focus is CGI matching, EtherCAT, move programming, robot safety, and target tracking, while it also touches on track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
21. Nodal Offsets

AI Summary
How to measure the lens nodal offsets for accurate Filming and Export from Flair.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, import/export, move programming, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 2 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
22. Rig Model and Animation

AI Summary
The use of the Rig model to see your moves, and an Introduction to Animation.
For operators using this as a reference, the main focus is move programming and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 7 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:13 — okay if I have my kinematics set so that I'm a master is extend rather than track
- 01:00 — there we are I'm now going to pull out slightly using the track button so I'm
- 02:06 — now I have a hundred frames between each of these I'm going to scale that move to
- 02:54 — machine that I can zoom in on and I can also move around if I me too and I can
- 03:59 — go to one frame per second and I'm going to scale my move to fifty frames
- 04:50 — step it will take a frame and move and
- 05:44 — step and have some kind of delay built in before our move continues we can put
23. From Flair to Maya (Part 1)

AI Summary
In this tutorial, we learn how to import an FBX with a camera movement from Flair into Maya, including setting up an image sequence as an image plane using a bloop light.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, firmware flashing, import/export, and kinematics, while it also touches on move programming, synchronization, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BLOOP_LIGHT and BOLT, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
24. From Flair to Maya (Part 2)

AI Summary
In this part of the tutorial, we learn how to use reference points taken on set, to align an exported camera movement; we also see how to quick fix a camera animation for rough composition purposes.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, import/export, kinematics, and move programming, while it also touches on robot safety, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 20 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:00 —
- 00:03 — welcome back to part 2 of this tutorial importing camera movements
- 01:19 — contextualize the camera movement
- 01:50 — position them in the right place
- 03:35 — set up three camera positions with the rig
- 08:46 — duplicate at frame 0 another locator
- 09:21 — select each locators
- 10:21 — move them along the z axis
- 13:04 — align your camera movement to the geometry
- 14:19 — align the camera to the geometry
- 14:57 — move the locators
- 17:04 — create a a single group containing reference points
- 18:47 — snap it to these locators
- 21:16 — rotate a bit
- 23:01 — calibrate the camera properly with lens
- 25:09 — animate the offset of your camera
- 25:16 — animate the offset in order to match the camera movement better
- 25:47 — analyze the footage
- 27:31 — select back the rotation of the camera group
- 32:05 — start setting up lighting and shadows
25. Long Arm Milo Introduction

AI Summary
The Long Arm version of the Milo, Takes a lens to 6 metres up with Precision.
For operators using this as a reference, the main focus is move programming, robot safety, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
26. FBX Import to Bolt Pedestal

AI Summary
In this tutorial learn how to load an FBX file to Flair for the Bolt on Pedestal.
For operators using this as a reference, the main focus is EtherCAT, Maya workflows, import/export, move programming, and robot safety, while it also touches on track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, CAMERA_RED, and PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 10 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:03 — so in this video we're going to be importing our three mode FBX file into a
- 00:51 — positions that may change as soon as we do an import because we're being porting
- 01:38 — version is fully licensed to use FBX so
- 02:41 — that onto my pedestal I can see that I obviously me to move in why probably by
- 04:16 — do this there are two solutions to a an import here and the mathematics can
- 05:24 — managing to do there but I'm getting close to running my move correctly I
- 07:39 — tilt 90 so what I'm going to do is I'm going to go back to my import let me
- 08:38 — that is successfully running the move
- 11:00 — let's have a look and see if I can actually run that says it's too fast but
- 12:08 — 180 frames just to see if that will stretch my move and make it more
27. FBX Import to Bolt on Track (Part 1)

AI Summary
In this tutorial learn how to load an FBX file to Flair for the Bolt on Track (Part 1).
For operators using this as a reference, the main focus is EtherCAT, Maya workflows, import/export, motion smoothing, and move programming, while it also touches on target tracking, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, CAMERA_RED, and PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 16 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:03 — we're now going to try importing that same move into a ball contract bear in
- 00:51 — up let's have a look at our rig model there we are both on track top mounted
- 01:41 — there's my move there now at first I'm
- 02:27 — import if I look now at that move on my
- 03:27 — what I am importing this choice of using track as a master may not be the optimum
- 04:22 — to rotate my move about my 0 by 90
- 05:14 — points but is actually located on the rail itself now if I try to run that
- 06:18 — possibility of going to arm master so that the track is actually part of the
- 07:25 — is out here so I will be able to better reach and do things and my track is
- 08:12 — let's put 0.8 there and do my import
- 09:00 — move there where my tilt tilts up
- 10:15 — am actually hitting with the camera to solve that problem I need to move my arm
- 11:12 — they're showing me that I have actually reached the move position correct let's
- 11:58 — too fast there by six times it wants to
- 13:09 — let's now just as an experiment stretch part of our move let's go from Waypoint
- 13:57 — fast for the track at with the
28. FBX Import to Bolt on Track (Part 2)

AI Summary
In this tutorial learn how to load an FBX file to Flair for the Bolt on Track (Part 2).
For operators using this as a reference, the main focus is Maya workflows, axis limits, import/export, move programming, and track calibration, while it also touches on zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT and PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 12 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:03 — I think we can safely say that because of the restrictions in the speed of the
- 00:51 — back to a track master this means that
- 01:47 — again there we are again here we have the move but here we have the arm being
- 02:37 — I need so it looks like what I need to do is add some track positions and
- 03:27 — to our start position and I am within reach of the position of the move and I
- 04:14 — forward that way so maybe instead of using 100 and zero I should use 130
- 05:13 — later position let's make it there instead I could of course re-import with
- 06:01 — not exceeding position you made me play him anyway let's try running that track
- 06:47 — total move if we accepted this fastest
- 07:40 — hitting anything without tripping my axes without meeting any limit or speed
- 08:28 — could only create a move that you he
- 09:21 — could put master axes in place in order to prevision eyes the move before
29. Exporting FBX with reference points from Flair to Maya

AI Summary
This tutorial goes over exporting an FBX file from Flair with reference points and then importing it to Maya.
For operators using this as a reference, the main focus is CGI matching, EtherCAT, Maya workflows, import/export, and kinematics, while it also touches on move programming, target tracking, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and PRECISION_TRACK, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 12 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:07 — in this tutorial i will show you how to export reference points
- 00:59 — got blue plate and frame number zero so zero from 99.
- 01:47 — the fbx the first thing i notice is that
- 02:57 — and watch the tutorial the previous tutorial on how to import reference
- 04:11 — tweak the camera animation in order to match properly that offset
- 04:58 — before shooting a motion control move
- 05:46 — quite accurate and that the kinematic also are probably quite
- 06:40 — right the next thing that i want to do is to import a
- 07:26 — a geometry to survey data
- 08:12 — 3d geometry
- 09:21 — let's look at the geometry for a top
- 10:24 — what i would do is to select the camera node the group node of the camera
Simul8 Tutorials
Maya/Simul8 tutorials for path creation, smoothing, camera head setup, RigMover nodes, limit checking, kinematic import, and 3-node camera animation in cartesian space.
1. Simul8 Tutorial: Introduction

AI Summary
In this Simul8 tutorial learn what Simul8 for Maya 2018/19 has to offer.
For operators using this as a reference, the main focus is CGI matching, EtherCAT, Maya workflows, axis limits, and import/export, while it also touches on kinematics, mimic systems, motion smoothing, move programming, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, MIMIC, PRECISION_TRACK, and TURNTABLE. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 13 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:10 — in this tutorial I will introduce you to simulate simulate is a plugin from Maya
- 01:36 — of the camera and so on in order to input rig right click on import rig
- 02:54 — allow for 20 centimeters this is usually the height of the rail once again
- 04:55 — camera and then select the remove the rig mover node and constrain it to it so
- 05:47 — after that you can apply to the silver in order to move the rig to match the
- 06:34 — limit the minimum limit is not infinite
- 07:21 — the viewport and then as I can move the truck further
- 08:08 — what I can do now is export this reg
- 08:57 — the operator now is going to be ready to import the move and mimic and run it and
- 09:52 — flour and there will be a velocities and acceleration maximum FPS which are as I
- 11:07 — and I can see through the limit try to
- 12:22 — know for example rig turntable or something that you want to keep track of
- 13:07 — so the next step the next step would be select this rig and import about clear
2. Simul8 Tutorial: How to Install Simul8

AI Summary
In this Simul8 tutorial, you'll learn how to install Simul8 and request a license. After that, you'll be all set to start using it in Maya 2018/2019.
For operators using this as a reference, the main focus is Maya workflows, import/export, and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
3. Simul8 Tutorial: Path Tool

AI Summary
Technical tutorial containing timestamped references for EtherCAT, Maya workflows, axis limits, import/export, motion smoothing.
For operators using this as a reference, the main focus is EtherCAT, Maya workflows, axis limits, import/export, and motion smoothing, while it also touches on move programming, spline behaviour, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_ARRI, CAMERA_RED, and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 7 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
4. Simul8 Tutorial: Smooth Tutorial

AI Summary
Technical tutorial containing timestamped references for Maya workflows, import/export, motion smoothing, move programming, spline behaviour.
For operators using this as a reference, the main focus is Maya workflows, import/export, motion smoothing, move programming, and spline behaviour, while it also touches on target tracking and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:07 — in this simulate tutorial I will show you how to use the smooth tool in the
- 01:00 — pond that looks like a city drawbacks off camera tracking however is that when
- 01:56 — you're gonna have that time trying to run that move you got smoothing in Fleur
- 02:44 — smooth tool and as you can see the
- 03:30 — translate and then I'm gonna buffer it and press the smooth button the first
- 04:15 — there are director cases where you want the extremes of the curve being the same
- 05:02 — want is the curve to maintain this
- 06:21 — planning it then it would create a nice little curve around it and that's
5. Simul8 Tutorial: Span Tool

AI Summary
In this Simul8 tutorial, you'll learn you how to use the Span tool in order to re-sample portions of "baked" fcurves in Maya 2018/19, so that they will follow a cubic curve kind of interpolation in-between the boundary keyframes of the selected portion of curve.
For operators using this as a reference, the main focus is Maya workflows, import/export, motion smoothing, move programming, and spline behaviour, while it also touches on target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:25 — solving version of the license and they allow you to move and interact with
- 02:15 — and that press expand that will basically try to follow the curvature of
- 03:06 — these two it's very important you understand that it's not gonna follow
- 03:53 — in the gap of the key frame selected so I said I want to follow curvature from
- 05:32 — three because we want them flat but i will set up the rest of the curve and
6. Simul8 Tutorial: Camera Head Tool
AI Summary
Technical tutorial containing timestamped references for EtherCAT, Maya workflows, axis limits, import/export, motion smoothing.
For operators using this as a reference, the main focus is EtherCAT, Maya workflows, axis limits, import/export, and motion smoothing, while it also touches on move programming, spline behaviour, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 16 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 04:48 — are moving so you would expect only to move the rotates a really the same
- 05:47 — without changing there is oh the rotate order can be found in the transform node
- 06:33 — if you want to move a pan or you want to
- 07:29 — objects each one with one single access so basically what is doing these node
- 08:19 — perspective view here right then what I would do I would select the parent node
- 09:07 — out of nodes and shows your be better how Maya works behind the wood this is
- 10:12 — reason why I will show you later this is a transform node
- 11:15 — is basically having related to the orientation of Maya the global space the
- 12:43 — baked the animation but I left the import active on so I will switch this
- 14:13 — me hide the original camera when I select the camera head node till
- 16:11 — keyframes at the end and at the start of your keyframe selection so now I've
- 17:04 — you see you will see that the purple is they camera head node the one that we
- 19:10 — actually that's back to 100 if I was to create a camera head node on a scaled
- 20:11 — as it stands at the moment the camera had to doesn't keep track of rounds in
- 21:52 — happening here is that is basically not filtering for Euler rotation as Maya
- 22:58 — linear well not really linear but like you've got like a continuous curve which
7. Simul8 Tutorial: RigMover Node

AI Summary
In this Simul8 tutorial, we show you how to use the rigmover node. The inverse kinematics solver that allows you to easily animate in 3D any MRMOCO rig.
For operators using this as a reference, the main focus is EtherCAT, Maya workflows, import/export, kinematics, and move programming, while it also touches on spline behaviour, target tracking, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 30 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:16 — kinematics over that comes with simulate plugin for Maya
- 01:11 — you very briefly all these buttons what they do and how to import rigs and
- 02:22 — the camera that you want to apply the rig move a node to and then ctrl select
- 03:21 — as many notice I'm just going to isolate these rig move a node arrow this
- 04:25 — move manoda the move mode is in track
- 05:13 — for extent angle are at zero and that is
- 06:00 — below the zero what I do is to translate
- 07:36 — and animating all the other axis for you because it's an inverse kinematic so the
- 08:59 — not influence this over okay back to the move what you would typically do let's
- 09:53 — what I can do I've got my first keyframe here you can
- 10:58 — based on the track hint values I gave
- 12:21 — just gonna put the extent back in let's start like that and keyframe it at the
- 13:19 — to show you now is if I back go back to the move mode truck the truck mode let's
- 14:21 — down the ad should be down the at the custom attributes in the rig-move mode
- 15:50 — inclination related to the truck sorry the rail so these are 2 different angle
- 17:05 — line along the left axis what it does is basically with zero on the horizontal
- 18:39 — going through the gimbal so you probably want to either move the camera in this
- 19:26 — can be useful sometimes since we are in move mode truck at the moment I'm going
- 20:15 — I want the base to follow the other side
- 21:38 — back to the other side that option obviously only works when move mode
- 22:46 — say that that's about a feature is the silver is gonna be keeping track of the
- 24:02 — better what I mean so I'm going to detach the rig mover node from the
- 25:38 — on rotate as well and on row so remover select the node and then in rig mover
- 27:45 — alike a cash cow affordable X when they get imported and the rig move or get
- 31:22 — truck at the beginning at the end of the move and now the truck is basically
- 34:55 — it when it's gonna be imported into my you'll see you will have LW rail objects
- 36:26 — top of this one next so at the moment to change the distance of the tilt node
- 37:11 — measurement the rig move our node and the place is where to do that is from
- 38:10 — and hence the translate Y will be negative oh five in the rig mover node
- 39:00 — seems quite okay so from here I can then do what I want I can move the rail I can
8. Simul8 Tutorial: Limit Checker

AI Summary
In this Simul8 tutorial, you'll learn how to use the limitChecker node in order to check how fast the rig can perform the animation provided.
For operators using this as a reference, the main focus is EtherCAT, Maya workflows, axis limits, import/export, and kinematics, while it also touches on motion smoothing, move programming, robot safety, spline behaviour, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 36 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:09 — simulator tutorial I will show you how to use the limited checker node
- 01:14 — their script editor there and the graph editor node which is already here
- 01:59 — panel's layout as my solving panels layout as I like right the limit checker
- 02:52 — that you need in order to solve and so for velocity is acceleration and values
- 03:41 — node and what I want to do it's to first
- 04:27 — speed and acceleration based on what
- 05:24 — display icon in the time slider you can access to a playback speed menus or sub
- 06:12 — with that speed or actually hitting one
- 07:07 — the first thing that you want to do after you've selected a limit checker
- 07:56 — moment I'm using only the track because
- 08:42 — you will find under the limit checker
- 09:30 — set the velocity of box velocity of the
- 10:15 — like that so if the velocity of the
- 11:27 — motors so it's dirty as a safety measure so it's more like an
- 12:19 — you look down the channel box the input truck acceleration fps is 19 is 19 frame
- 13:11 — acceleration and deceleration issue that
- 14:04 — to specific basically specific to their own access so truck will have from zero
- 14:52 — compound to our velocity and
- 15:52 — velocities has been computed and acceleration has been computed too so I
- 16:38 — the rail so with one piece of we won the
- 17:49 — locator of the Ren's nose is the zero of the truck so
- 18:37 — the limit values of the limits of my
- 19:23 — warnings about the acceleration of the
- 20:11 — probably check that the value of the rail is now 68 centimeters against the
- 21:01 — velocity rover or acceleration of the
- 22:05 — say take out 10 centimeters from truck trouble still a bit still a bit too fast
- 23:31 — would do in flair about velocities and acceleration per axis the only thing
- 24:24 — for truck red is position Green is the velocities blue is acceleration and what
- 25:09 — for I use more smooth it's blind so it
- 26:00 — they're mathematically speaking is there and the enemy checker node picks it up
- 27:12 — the tangent so I will hide them select it and buffer the queue buffer the curve
- 28:00 — so these values 1 9 1 meter 98 and the original value before the smooth was 1
- 28:49 — the acceleration and deceleration it's
- 29:41 — different mathematics behind the spline
- 30:28 — the viewport in Maya especially with
- 31:17 — check what access are giving you warnings through the limit check it out
9. Simul8 Import kinematics tutorial

AI Summary
In this Simul8 tutorial we'll show how to import kinematics and axis limits from Flair to Simul8 in order to have matching values on both systems.
For operators using this as a reference, the main focus is EtherCAT, Maya workflows, axis limits, import/export, and kinematics, while it also touches on motion smoothing, move programming, target tracking, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:15 — features introduced with version 1.0.5 import rig kinematics from flare and
- 01:04 — if you want and they should be the same let's close this and go to maya
- 02:45 — everything accordingly to that however in maya the height of the base
- 03:44 — that in these flair kinematics setup the height of the rail from the ground
- 04:40 — different and then import it back to
- 05:47 — over to your rig mover shape node in to
- 06:35 — it's it's for fur so what you want to do it's very similar to how to export the
- 08:00 — nothing to change here it looks all right so let's open maya
- 08:53 — i've got different velocities and different acceleration let's double
- 10:44 — through camera height at zero if you remember from robot kind
- 12:18 — is not going to be like the camera height at zero value is not going to
10. Simul8 Tutorial: 3 node camera animation in carts

AI Summary
In this tutorial we’ll show how to export a 3 node camera animation in carts from Simul8 to Flair.
For operators using this as a reference, the main focus is CGI matching, EtherCAT, Maya workflows, import/export, and move programming, while it also touches on spline behaviour and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 18 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:07 — control in the simulated tutorial i will show you how to export a camera movement
- 00:59 — a camera aim and up in maya
- 01:56 — i'll delete this you won't need a three notes camera in maya in order to
- 03:02 — let's parent constraint remover node to the
- 03:58 — um let's keep the track here
- 04:56 — bake out or export a move frame by frame so
- 05:50 — rig root node
- 06:38 — check on the keyframes for sparse export
- 07:24 — just got two lines of data inside my exported move
- 08:16 — so same rig remover node
- 09:03 — good cards that is basically very close to our export from maya
- 09:49 — access and in the cgi imports window
- 10:42 — relation to the note the three camera node are the
- 11:29 — so as you can see now on the track i've
- 12:27 — going to ask us to you know reframe or move and
- 13:39 — the lens node offsets it's still the same 24 and
- 14:38 — the curves that are linking the two keyframes in maya
- 15:23 — you import it and that is because of the
Flair 7 Training Videos
The official MultiDyne-maintained Flair 7 training playlist covering Flair startup, zeroing and limits, target tracking, cartesian control, animation, live view, the Tracker App, probe-lens calibration, stop-frame animation, and related workflows.
1. Starting Flair & Overview

AI Summary
A video covering starting Flair 7 & overview.
For operators using this as a reference, the main focus is CGI matching, move programming, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI, PRECISION_TRACK, and TURNTABLE, and software/version references include Flair 1, Flair 2, and Flair 7, and the working environment is Both. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 7 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
2. Setting up Home, Zero & Limits

AI Summary
A video explaining the background of Home, Zero and Limits and how to correctly set them in Flair 7 with the Cinebot.
For operators using this as a reference, the main focus is CGI matching, axis limits, move programming, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI and PRECISION_TRACK, and software/version references include Flair 4 and Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
3. Estimate Target

AI Summary
A short video covering a very useful feature in Flair called "Estimate Target".
For operators using this as a reference, the main focus is move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
4. Limits of the rig during Moves & Browsing
AI Summary
A video demonstrating rig limits during moves and handheld controller browsing.
For operators using this as a reference, the main focus is HHB, motion smoothing, move programming, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and HHB. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:15 — want to explain the difference between the handheld
- 01:15 — it can become dangerous doing it while moving it manually whereas in a move
- 02:12 — slowly creeping along very slowly just going to speed up a
- 03:01 — move and
- 03:54 — at round about there it turns blue indicating that it's going too fast it's
- 05:04 — positional limits this is my velocity limits and
- 06:12 — something is too fast uh it's important to heat it but
- 07:03 — potentially tip over so generally speaking whenever you run a move you
5. What is MRMC's Target Tracking and how to use it

AI Summary
A video explaining MRMC's Target Tracking and how to use it.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, motion smoothing, move programming, and target tracking, while it also touches on track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:10 — something about uh what we call Target tracking Target tracking was developed
- 00:57 — nowadays in 3D uh uh programs and CGI
- 02:06 — and free Drive good so I have a simple two-point move if I look at it
- 02:58 — obvious uh so I'm going to adjust my move even further
- 05:08 — cm okay so what I do uh I'm at the end of my move so I'm going to type here
- 06:17 — have seen that my focus didn't adjust to my focus uh earlier when I ran the move
- 08:11 — roll is set to relative which it can't do when it's not in Target tracking so
- 08:57 — two target positions because each key frame or Waypoint has its own Target
- 10:29 — created a key frame yet I'm going to create now so add a new Waypoint way
- 11:17 — accelerating and this is effectively by this is 49% too fast or over
- 12:23 — okay so with regards to Target tracking you can always measure with a
6. How Kinematics relate Target Tracking

AI Summary
A video explaining what is the kinematics file in relation to target tracking in Flair.
For operators using this as a reference, the main focus is CGI matching, import/export, kinematics, move programming, and target tracking, while it also touches on zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:05 — in an earlier video we looked at a Target tracking move and we showed how
- 00:52 — roll moves then the move that we get
- 01:38 — that I'm going to turn on target tracking again I'm going to turn on Roll
- 02:27 — to so we're in the home position and
- 03:54 — and we can do that right the way through the move these axes of motion are
- 05:54 — that we need to do so this file is specific to the Target tracking axis if
- 06:41 — time or go on a remote location and shoot the same move again in order to
- 07:28 — position is with regard to the rest of the rig of otherwise the target tracking
7. Use of Carts, Master Axes and editing move timings

AI Summary
A video on the use of Carts, Master Axes and editing move timings in Flair 7.
For operators using this as a reference, the main focus is CGI matching, axis limits, move programming, spline behaviour, and target tracking, while it also touches on track calibration and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Both. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 21 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:07 — we have six axes in order to make this target tracking work but on this
- 00:53 — handle that in a specialized way if the track axis here were merely a Target
- 01:40 — tracking and if I want the camera to be
- 02:31 — where that is and set up my move so here I
- 04:07 — pull so I'm now in a position where I can if I wish move on to create my first
- 04:54 — there so while still in carian control I'm going to move my track
- 05:57 — close to camera pan being zero in I'm looking there I'm
- 06:45 — again I'm going to move back in x a
- 07:37 — view just to make sure it does actually run the track is doing its own thing
- 08:43 — to store a position there now I have a nice curve move in
- 10:17 — shoot okay so I have that move the
- 11:19 — extend the camera there back along the track as it happens I don't have much
- 12:08 — now and if I back run that yes I'm getting close to the limit
- 12:57 — that so now we have 150 frame move and that frame that
- 14:00 — there so I have actually changed the curve of
- 14:47 — that number just as well but that is giving me a more curve more of a curve
- 15:55 — nice nearly straight line there and a nice curve there and this is suitable to
- 16:41 — will not change the curve if I have a a
- 17:29 — by changing my move frame rate if I
- 18:21 — experiment so now it's now 100 frame move uh sorry it's now a 240 frame move
- 19:07 — takes place but it is exactly the same curve and those two curves on a
8. Focus modes in Flair 7

AI Summary
A video explaining the different Focus Modes in Flair 7.
For operators using this as a reference, the main focus is move programming and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:50 — you can measure it's an independent axis so it's not going to follow the
- 01:36 — Target situation and we can now look at this move I have a twoo move there I'm
- 02:22 — move if I want to do that I'm going to
- 04:35 — independent axis if that was a Target tracking axis if any of these other
- 06:09 — middle and my focus is an independent axis that is set to follow his object
9. Fairings - A Basic Explanation

AI Summary
A video explaining what are Fairings and how are they used.
For operators using this as a reference, the main focus is motion smoothing, move programming, pre/post-roll, spline behaviour, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes TURNTABLE. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:14 — confusion about them fairings also known as eases are the way that the curve
- 00:59 — the fairing here and there and apply it and it will adjust my curve or I can
- 01:47 — up with what is called a spline a spline
- 02:49 — now now if there is an actual change in Direction let's move this out the way
- 03:34 — section and decreasing in speed and if I
- 04:19 — I can force it to put a spline through
- 05:13 — stop because it's changing direction it never if you run the move never quite
- 06:03 — percentages to zero so if I change that to zero and
- 06:51 — starts at frame zero before frame zero
- 07:37 — one okay you'll see effectively my velocity my speed is constant throughout
- 08:30 — you'll see here it'll say pre-rolling when it's at frame zero then it'll run
10. Fairings Axis & Cartesian

AI Summary
A video explaining the Fairings Axis and Cartesian in Flair 7.
For operators using this as a reference, the main focus is motion smoothing, move programming, pre/post-roll, spline behaviour, and target tracking, while it also touches on track calibration and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK and TURNTABLE, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 13 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:12 — fairings also known as eases or ease in and ease out um but I've got a move
- 01:10 — there are only two key frames or there is a change in Direction then the spline
- 02:06 — the cartisian fairings these are to do with Target tracking axes so if we look
- 03:10 — frames you have a an acceleration okay so here for 23% of
- 04:24 — almost a corner here because it approaches this with a constant speed
- 05:11 — see that there is a very Sudden Change in speed for most of the axes then a
- 05:57 — Waypoint so in my cartisian Waypoint I
- 07:26 — the in the fairings menu is there is something called Curve reversal
- 08:49 — and then it overshoots it goes beyond it it will look nice and smooth but it may
- 09:36 — okay that's the point of curve reversal
- 10:37 — to start off with a simple two-point move so for example if I remove my
- 11:26 — apply you'll see this Curve will
- 12:17 — okay and shoot does a little pre-roll
11. The Four Main Cartesian Control Modes

AI Summary
A video covering the four main Cartesian Control Modes in Flair 7.
For operators using this as a reference, the main focus is motion smoothing, move programming, target tracking, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:11 — in order to be able to do correct Target tracking this particular rig amongst the
- 01:05 — motion if you look at this it has Target tracking it's a Target tracking type
- 01:53 — locked level or relative in in order to do the target tracking it is called a
- 02:39 — tracking is a capability to move around
- 03:59 — Zed and the world cartisian is a universe that is aligned with the rail
- 04:46 — in y my camera moves in a straight line across the rail he's moving in a
- 05:33 — the rail so the camera is moving
- 07:58 — world the camera and Target are locked together so if I move in
- 08:54 — the two are staying in parallel to the rail if I move in Zed again the camera
- 11:03 — in locked View and my target is going to move with the camera because they are
- 12:30 — common uh systems for finding way points in order to do normal Target tracking
12. Axis vs Cartesian Priority

AI Summary
A video explaining the difference between Axis Priority and Cartesian Priority in Flair.
For operators using this as a reference, the main focus is move programming, target tracking, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:16 — fully understand it. Flare when you create a move stores the
- 01:01 — track is because the track is what we
- 01:47 — Okay. But my track if I move it
- 02:34 — adjust the move. But if I just adjust it
- 03:25 — >> okay, and now I go into cartisian control and adjust my track.
- 04:12 — Now if I now adjust one of these, let's say I move my lift up for whatever
- 05:19 — convert these back into axes using this new track value.
- 06:49 — So this is my move.
13. Different Roll Modes

AI Summary
A video describing the different roll modesin Flair.
For operators using this as a reference, the main focus is EtherCAT, Maya workflows, import/export, move programming, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
14. Animation, Timelapse & Part Runs

AI Summary
A short video describing the Animation, Timelaps & Part Run options in Flair 7.
For operators using this as a reference, the main focus is HHB, move programming, pre/post-roll, synchronization, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
15. Profiles in Flair

AI Summary
A video covering how to manage different profiles in Flair.
For operators using this as a reference, the main focus is HHB, hot booting, import/export, and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:43 — could then set hit set active and flare will restart into that profile. Uh and
- 01:29 — By reverse, if you want to import a profile, you use
- 02:17 — for flare bridge. If you want to overwrite and import the HHB
- 04:19 — versions of Flare, maybe different rig models, and move them to other devices
16. Explaining the 3D Rig model display in Flair 7

AI Summary
A video explaining the 3D Rig model display in Flair 7 and how to use it.
For operators using this as a reference, the main focus is Phantom workflows, import/export, move programming, robot safety, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_PHANTOM and CAMERA_RED, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 9 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:15 — have a 3D model of your rig your move and lots of additional information
- 01:06 — Backwards I can pause it carry on okay I can also make it just repeat
- 03:19 — a line all the way through the move of what the camera is doing
- 04:42 — view okay next we can import 3D rig models I have one here
- 05:50 — is so let's say I want to be 2 m to the side of my rail minus 2
- 06:43 — what you can also do is you can also move the model on the screen
- 08:00 — those older members of the public amongst us and then there's a Phantom
- 09:06 — this is what it looks like from the top and this is my move from the
- 09:52 — is what it's going to see as I run that move so you can actually simulate moves
17. RED Komodo & Raptor Syncing

AI Summary
A short video showing how to connect the RED Komodo (or V-Raptor) and the Raptor XL to Flair.
For operators using this as a reference, the main focus is Network Direct, Phantom workflows, move programming, and synchronization. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, CAMERA_PHANTOM, and CAMERA_RED, and software/version references include Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
18. The Waypoint View in Flair 7 explained
AI Summary
A video explaining the Waypoint View in Flair 7.
For operators using this as a reference, the main focus is motion smoothing, move programming, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, CINEBOT_MINI, PRECISION_TRACK, and TURNTABLE, and software/version references include Flair 7, and the working environment is Both. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 26 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:08 — okay so I'm going to run through the Waypoint display here I make it full
- 01:26 — store and then add a point and move it
- 02:24 — okay these are the shortcut buttons so this is delete Waypoint and this is to
- 05:34 — can use this slider okay this here allows you to move the axis it's like a
- 06:20 — move side to
- 07:07 — down speed up a bit more speed up a bit
- 07:57 — run uh once I unlock it it's then free to move okay
- 08:45 — position it just goes to it it'll take my rotate to zero or I can tell it to go
- 09:48 — here on the rotate uh go to home I can access from
- 11:41 — okay uh as I said the menu changes so for example the track axis has different
- 12:41 — region which you can set where that region is but effectively as I move it
- 13:36 — checkboxes are whether the axis is on or off so for example my track is off at
- 14:58 — very useful unless you want to make sure nobody Chang es anything or doesn't move
- 16:28 — to note that whenever you use these buttons here to move the rig these this
- 17:23 — sensible so now if I go into my cartisian mode to move the camera around
- 18:19 — tilt pan doesn't pan all the axes are at strange angles and when you try and move
- 19:10 — before I do that I'm going to go to this Waypoint view
- 20:12 — well um then we've got show Waypoint images
- 21:02 — to say that you know this is uh this is the Waypoint where the actor enters
- 23:53 — buttons uh effectively as we did in the vertical Waypoint display except for
- 24:55 — to copy waypoints if I want to copy uh Waypoint one to here I just type in one
- 26:12 — waypoints so the same Waypoint menu as
- 27:28 — going to that was just going to start that wasn't the actual move uh but my
- 28:26 — priority to cartisian axis that means it will run the move that's here rather
- 29:46 — it because I'm at the end it'll go 5 cm down but then during the move it'll
- 30:39 — so forward run starts 5 cm high and then during the move goes 5 cm
19. The Runtime/Timeline display in Flair 7
AI Summary
A video covering the Runtime/Timeline display in Flair 7.
For operators using this as a reference, the main focus is CGI matching, HHB, motion smoothing, move programming, and pre/post-roll, while it also touches on synchronization and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and HHB, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 19 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:28 — go full screen here on the key on the key frame display or Waypoint display
- 02:12 — button you have may have programmed onto your handheld controller Gamepad or
- 03:51 — on so now I can it's controlled and let's I'll move it to
- 04:44 — frame okay you can even adjust the timing so you can drag this Waypoint
- 05:48 — you do a part run the move between frame 30 and frame
- 07:03 — okay and you will see there will be a small pre-roll and then a slightly
- 07:49 — zero and frame 150 I just press that and
- 09:16 — actually browse which I'll show you in a minute uh or run the move okay so
- 10:12 — browse you either just forward run to go into running the move or you just press
- 11:00 — so I've reached the end of my move
- 12:00 — your camera back on ready for the next take okay if you don't like the speed
- 12:47 — because I can take one step forward okay and if I do that it'll move one frame
- 14:59 — button each time it'll do a pre-roll and a post
- 16:06 — not going over position but it is going too fast over velocity and is going over
- 17:04 — okay these buttons here will affect the move either by slowing it down to 22
- 18:20 — slide uh or shift and that means that your passes will no longer match your
- 19:10 — speed okay last then next we have the
- 20:12 — that the exposure will happen exactly the same place in every move it's very
- 21:06 — do with a move okay next we have the
20. Live View Display in Flair 7 & Focus Assist

AI Summary
A video covering the Live Vew display in Flair 7 and also the Focus Assist module.
For operators using this as a reference, the main focus is HHB, move programming, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 12 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 01:23 — set just leave it at device zero
- 02:30 — just to explain these buttons here move the camera in
- 03:23 — axis okay if I just take it back to my start position of my move that I had
- 04:22 — doing okay this one will move in an arc
- 05:29 — just adjusts that because it knows where my target is based on the Move I've
- 06:36 — use my rotate to move my individual axis so now
- 09:17 — axis and right click I have this option here Focus follow
- 11:29 — position it'll also at that whenever I click on it also move the focus to that
- 12:52 — okay here is my move okay and you can see the background
- 13:52 — does give you a good indication of what the move is going to be so if you have a
- 14:46 — iPhone the address of where to get this video feed from so that as you move the
- 17:33 — going to make it larger so that's how I move it around
21. Keyboard & Mouse shortcuts in Flair 7

AI Summary
A video showing the many keyboard & mouse shortcuts that are available.
For operators using this as a reference, the main focus is HHB and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 10 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
22. File Menu & CGI Import/Export

AI Summary
A video explaining the File menu of Flair 7 and the many options when exporting and importing moves.
For operators using this as a reference, the main focus is CGI matching, EtherCAT, Maya workflows, axis limits, and hot booting, while it also touches on import/export, mimic systems, move programming, spline behaviour, and synchronization. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BLOOP_LIGHT, MIMIC, PRECISION_TRACK, and TURNTABLE, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 7 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:00 — Intro
- 00:13 — New, Reset All & Save – how changes to settings are saved and recalled
- 04:00 — Job Storage, Recent Jobs & Load Simple Job
- 05:43 — Reload Current Job, Append Job, Merge Job
- 09:38 — Exporting a Move & options
- 16:43 — Importing a Move & options
- 26:13 — Exporting & Importing Configuration data
23. Help Menu in Flair 7

AI Summary
A video explaining the Help Menu in Flair 7 including how to send a software bug report and license request.
For operators using this as a reference, the main focus is move programming and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
24. Handheld Controller Setup in Flair 7
AI Summary
A short video explaining how to set up a wired hand controller (HHB) such as a game controller.
For operators using this as a reference, the main focus is HHB, move programming, robot safety, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and software/version references include Flair 5 and Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
25. Goto Menu & Goto Browsing

AI Summary
A video describing the Goto Menu options in Flair 7.
For operators using this as a reference, the main focus is move programming, pre/post-roll, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
26. Adding a Network Node in Flair

AI Summary
Adding a network node in Flair including.
For operators using this as a reference, the main focus is EtherCAT, Network Direct, firmware flashing, hot booting, and import/export, while it also touches on move programming, synchronization, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, BOLT_JR, PRECISION_TRACK, TRIGGER_BOX, and TURNTABLE. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 9 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
27. Connecting RED Camera Settings to Flair 7

AI Summary
A short video demonstrating how to connect your RED camera to Flair using RCP.
For operators using this as a reference, the main focus is Network Direct. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, and software/version references include Flair 5 and Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
28. Tracker App Setup (Windows)
AI Summary
This tutorial shows the complete Windows network setup needed to use an iPad running the MRMC Tracker App as a live controller for a robot in Flair. It explains why the real-time InTime-controlled robot network must be bridged to a Windows network connection and recommends using a small dedicated Wi-Fi router instead of a busy studio or office network. The configuration walkthrough covers enabling the InTime network bridge, assigning the Windows adapter a static IP address, editing netuser.cfg, and configuring a GL.iNet smart router with compatible LAN and Wi-Fi settings. It then connects the iPad to that wireless network and enters the Flair computer's IP address in the Tracker App. The final section opens the Tracker interface in Flair, selects the appropriate camera and scaling options, enables Mimic mode, and demonstrates the robot responding to movement of the iPad. Operators can use the chapter links to jump directly to the InTime, Windows, router, iPad, or Flair portion of the setup.
For operators using this as a reference, the main focus is Tracker App setup, Windows networking, and live control, while it also touches on InTime bridge configuration, static IP addressing, and Wi-Fi router setup. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes iPad, Cinebot Mini, and GL.iNet smart router, and software/version references include Flair Classic and InTime, and the working environment is Flair Classic on Windows. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 7 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
29. Tracker App Setup (Linux)

AI Summary
A video showing how to set up the iOS Tracker App with Flair 7 running in Linux.
For operators using this as a reference, the main focus is Network Direct, axis limits, move programming, target tracking, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
30. Tracker App Live Control

AI Summary
A video covering the options to live control the robot through the tracker app.
For operators using this as a reference, the main focus is mimic systems, move programming, robot safety, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and MIMIC. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
31. Tracker App - Record Vision
AI Summary
A video showing the "Record Vision" option of the iOS tracker app.
For operators using this as a reference, the main focus is import/export, mimic systems, move programming, target tracking, and track calibration, while it also touches on zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, MIMIC, and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
32. Calibrating a Probe Lens

AI Summary
A video showing the set up of a Laowa 24mm Probe lens in Flair 7.
For operators using this as a reference, the main focus is hot booting, move programming, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI, and software/version references include Flair 4 and Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
33. Stop-frame Animation in Flair

AI Summary
A video demonstrating the use of Stop-frame Animation in Flair.
For operators using this as a reference, the main focus is move programming, robot safety, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 0. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
34. Cinebots Kinematic Do Nots
AI Summary
A quick video showing situations that may get you in trouble with your Cinebot because of kinematics.
For operators using this as a reference, the main focus is kinematics, move programming, spline behaviour, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:26 — to go file new. So, I'm going to move it to a position
- 01:16 — able to reach that same position. Another thing not to do is to move the
- 02:30 — trying to go up and then halfway through the move instantly try and
- 03:52 — it. Thinks there's some kind of problem. It looks pretty simple that move. Okay.
- 04:57 — >> Okay. And this time I'm going to use these controls to move around my target.
- 06:05 — And it's not happy about it. It's not a big move, but it's not happy about it
- 06:52 — curve around it. But you need to be
- 07:58 — to save some time. Okay, so this is my move.
35. Camera Mounts & Offsets

AI Summary
A video covering Camera mounts & offsets in Flair.
For operators using this as a reference, the main focus is move programming and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:18 — instance have a very long probe lens and you wanted to move around the probe
- 01:07 — offset, which again there shouldn't be, that should remain zero, so you don't
- 02:08 — my film plane, so I'm not going to I'm just going to leave that at zero. And
- 03:25 — offset. And my Y is sideways, which is normally zero, but my Z is from that
Flair Lite & Nano Tutorials
Tutorials specific to Flair Lite and Cinebot Nano workflows: Tilta lens setup, PushMoco, keyframes and timeline, speed profiling along orbitals, and transport positions.
1. Flair Lite: Tilta Lens Setup
AI Summary
A video covering how to set up the Tilta lens motors in Flair Lite.
For operators using this as a reference, the main focus is CGI matching, EtherCAT, Network Direct, firmware flashing, and hot booting, while it also touches on lens calibration, move programming, robot safety, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 14 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:15 — then you do need to get the MRMC firmware and upgrade the firmware on the
- 01:35 — isn't enough room for the motor to get in there. So, we have a little adapter
- 03:10 — to the other end. You can see it move.
- 04:32 — to start first with the lens calibration.
- 05:37 — with the motor. The range should always be between zero and one. The lens
- 06:27 — if for example, infinity is at one and minimum focus is at zero, you
- 07:12 — And then I move it to the closest focus,
- 08:08 — to make sure that the focusing is better because it doesn't follow exactly what a
- 09:06 — see the numbers. So, you can see infinity zero and these are the other
- 12:57 — to there, but this is on center, so that remains a zero.
- 14:51 — target so the units are in centimeters, okay? And firstly, I can move it
- 15:47 — and it the unit will vibrate, and it will say here slave.
- 16:48 — So, disable it, okay, and re-enable it.
- 19:10 — the motor will do a rapid turn at some point. And then move it here using my
2. Camera Mounts & Offsets
AI Summary
A video covering Camera mounts & offsets in Flair.
For operators using this as a reference, the main focus is move programming and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:18 — instance have a very long probe lens and you wanted to move around the probe
- 01:07 — offset, which again there shouldn't be, that should remain zero, so you don't
- 02:08 — my film plane, so I'm not going to I'm just going to leave that at zero. And
- 03:25 — offset. And my Y is sideways, which is normally zero, but my Z is from that
3. Flair Lite - PushMoco & Waypoint Timings

AI Summary
A short video explaining how to use PushMoco on Flair Lite and adjust waypoint timings.
For operators using this as a reference, the main focus is axis limits, motion smoothing, move programming, robot safety, and spline behaviour, while it also touches on track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, CINEBOT_MINI, and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 15 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:33 — setups. I'm going to do sounds. Okay. And I'm going to select waypoint
- 01:36 — to stop it from moving. But it should be that when you enable it, it doesn't move
- 02:25 — audio is going to recorder not to a set of speakers. So I'm going to now move it
- 03:20 — see what that looks like in preview. So, this is my move.
- 04:11 — beginning. Remember, I'm at the end. So, it's going to do a straight line move to
- 06:50 — Good. And so now when I run it, it's in focus throughout my move. I haven't had
- 07:37 — will try and put a nice smooth curve
- 08:31 — that point. Okay. And if I now run this move
- 09:55 — I'm going to just go to the start of the move
- 12:12 — and the distance that travel is traveled in between affects the move right which
- 13:54 — far away from everything. But let's try and put an extreme move on this. Okay.
- 14:41 — problem running this move. Yeah, it's
- 16:04 — So that's not workable. So I wouldn't be able to do that move.
- 17:16 — >> And now it's >> it's doing a very different move, but it
- 19:31 — >> Okay. All I really do is adjust it. Okay. So, actually move it further away.
4. Flair Lite - Keyframes & Timeline

AI Summary
A video covering an introduction to Flair Lite including:.
For operators using this as a reference, the main focus is Network Direct, move programming, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 16 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:23 — go to the cog here. Uh it's coming in via a USB adapter. So, I'm going to
- 01:10 — difference between a key frame and a waypoint. Um it's it's the point that
- 02:25 — with these actual buttons here. For example, my track. If I move my track,
- 03:23 — Okay. Till I'm looking at my objects. Uh, if I want to move my camera
- 04:11 — So let's say there keep it simple. Okay. Move that. I can go to my this plus
- 05:16 — end point. Okay. Now, this is the start of the move. It'll go.
- 06:04 — And you'll notice at the start of the move, it instantly jumps to the
- 06:58 — status it says ready to go to. Now a goto is not a program move. It's not the
- 07:47 — miscellaneous setups, and change your go-to speed right down. Okay, apply.
- 08:33 — It's warning you that this could be fast because the rig can move fast. This
- 09:19 — is in the middle. And it says go to now. Because my go-to speed is still very
- 10:07 — store this. So to store it, I can either well all I've done is move my slider,
- 10:59 — uh method possible. Okay, I'm going to speed up my go-tos just so we don't
- 12:17 — it's in ready to shoot. So I press play and this is now the move running again.
- 13:19 — it'll completely ignore it. Okay. It won't try and move it. It'll just ignore
- 18:03 — ends there. Okay. Um if you want to um record the move onto your camera and
5. Speed along Orbitals & Speed Profiling

AI Summary
A short video by Assaff covering Speed along Orbitals and Speed Profiling in Flair Lite.
For operators using this as a reference, the main focus is CGI matching, move programming, spline behaviour, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and TURNTABLE. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 9 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 01:19 — my minimum focus. Okay. Don't need to be it then. Just move back a bit.
- 02:24 — We go. And it's now quite happy it's ignoring it. So this is my move.
- 03:24 — section. Okay. So, I'm going to just move them out a little bit more,
- 04:13 — Y and delete. Okay, good. So I'm back to my original move.
- 05:00 — move is 100 frames long.
- 05:46 — target. You can actually adjust the speed of the camera path and the target
- 06:43 — would mean it would actually get up to speed, come to a stationary point here,
- 07:33 — have a turntable uh moving or um some other axis moving. It'll speed profile
- 08:51 — All right. So, this will actually get up to speed, slow down, stop, go backwards,
6. Cinebots Kinematic Do Nots
AI Summary
A quick video showing situations that may get you in trouble with your Cinebot because of kinematics.
For operators using this as a reference, the main focus is kinematics, move programming, spline behaviour, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:26 — to go file new. So, I'm going to move it to a position
- 01:16 — able to reach that same position. Another thing not to do is to move the
- 02:30 — trying to go up and then halfway through the move instantly try and
- 03:52 — it. Thinks there's some kind of problem. It looks pretty simple that move. Okay.
- 04:57 — >> Okay. And this time I'm going to use these controls to move around my target.
- 06:05 — And it's not happy about it. It's not a big move, but it's not happy about it
- 06:52 — curve around it. But you need to be
- 07:58 — to save some time. Okay, so this is my move.
7. Cinebot Nano - Transport Positions

AI Summary
A video on how to put your Cinebot Nano into a position so that it fits into travel cases for transport.
For operators using this as a reference, the main focus is axis limits and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 2 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
8. Profiles in Flair
AI Summary
A video covering how to manage different profiles in Flair.
For operators using this as a reference, the main focus is HHB, hot booting, import/export, and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:43 — could then set hit set active and flare will restart into that profile. Uh and
- 01:29 — By reverse, if you want to import a profile, you use
- 02:17 — for flare bridge. If you want to overwrite and import the HHB
- 04:19 — versions of Flare, maybe different rig models, and move them to other devices
Cinebot Mini/Max & Flair 7 Training
Cinebot Mini/Max-focused training series covering unboxing and startup, payload calibration, moves with Push Moco, target tracking, fairings, triggers, the Tracker App, and Flair on Linux.
1. Unboxing the Cinebot Mini

AI Summary
A detailed video showing the unboxing of a CineBot Mini and setting it up for first time use. Also some notes on preparing it for transportation.
For operators using this as a reference, the main focus is Network Direct, axis limits, motion smoothing, move programming, and robot safety, while it also touches on synchronization, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BLOOP_LIGHT, BOLT, CAMERA_RED, CINEBOT_MINI, PRECISION_TRACK, and TRIGGER_BOX. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 17 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:00 — intro & opening crate
- 07:34 — Setting up the pinch wheel
- 08:35 — operating the wheel units
- 12:22 — Racking joiner & limit magnets
- 13:14 — Levelling the short piece of rail
- 14:42 — Adding the long piece of rail & levelling
- 25:52 — Using track bearing to smooth bearing rail (also showing OPTIONAL Spares package)
- 34:50 — Connecting the racking
- 37:19 — Adding Riser to track base & adapter plate
- 40:17 — Adding the arm to the track base
- 42:33 — Attaching umbilical to the track base
- 45:39 — Connecting the umbilical to the Operator control case
- 49:38 — Power On, confirm position, Homing arm
- 55:00 — Connecting arm cable set
- 57:36 — Attaching Camera platform
- 59:31 — Dismantling the system
- 01:02:06 — Preparing the base & rail for transport
2. Overview of the Cinebot Mini

AI Summary
A short video showing the different parts of the Cinebot Mini robot.
For operators using this as a reference, the main focus is move programming and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, CINEBOT_MINI, and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
3. Starting up the Cinebot Mini
AI Summary
This video shows the sequence to start up the Cinebot system.
For operators using this as a reference, the main focus is CGI matching, move programming, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI and TURNTABLE, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
4. Payload Calibration in Flair 7

AI Summary
A video demonstrating the new Payload calibration process through the Flair 7 interface.
For operators using this as a reference, the main focus is kinematics and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
5. Starting Flair & Overview
AI Summary
A video covering starting Flair 7 & overview.
For operators using this as a reference, the main focus is CGI matching, move programming, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI, PRECISION_TRACK, and TURNTABLE, and software/version references include Flair 1, Flair 2, and Flair 7, and the working environment is Both. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 7 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
6. Setting up Home, Zero & Limits
AI Summary
A video explaining the background of Home, Zero and Limits and how to correctly set them in Flair 7 with the Cinebot.
For operators using this as a reference, the main focus is CGI matching, axis limits, move programming, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI and PRECISION_TRACK, and software/version references include Flair 4 and Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
7. Setting up the Tilta Lens Motor
AI Summary
A video showing how to set up the Tilta Lens Control Motor with the Cinebot.
For operators using this as a reference, the main focus is lens calibration, move programming, spline behaviour, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and CINEBOT_MINI, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
8. Reversing the Lens Motor & Troubleshooting

AI Summary
Shows how to reverse the Tilta Nucleus-M lens motor direction in Flair, including motor numbering, port matching, disable/enable sequence, and drive-to-ends calibration.
For operators using this as a reference, the main focus is lens motor reversal, focus calibration, Tilta motor, motor port matching, and axis setup, while it also touches on Focus Follows Target and Focus Independent. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI, CINEBOT_MAX, and CINEBOT_NANO, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
No chapter headings were available for this video.
Chapters
- No chapter headings were available.
9. Camera Mounts & Offsets
AI Summary
A video covering Camera mounts & offsets in Flair.
For operators using this as a reference, the main focus is move programming and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:18 — instance have a very long probe lens and you wanted to move around the probe
- 01:07 — offset, which again there shouldn't be, that should remain zero, so you don't
- 02:08 — my film plane, so I'm not going to I'm just going to leave that at zero. And
- 03:25 — offset. And my Y is sideways, which is normally zero, but my Z is from that
10. Using Push Moco to create a Move
AI Summary
A video showing how to create a move using Push Moco on the Cinebot.
For operators using this as a reference, the main focus is move programming, robot safety, target tracking, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, CINEBOT_MINI, PRECISION_TRACK, and TURNTABLE, and software/version references include Flair 1. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 7 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
11. Using Push Moco to create a move incl track

AI Summary
A video showing how to create a move using Push Moco on a Cinebot Mini including track.
For operators using this as a reference, the main focus is axis limits, move programming, robot safety, spline behaviour, and target tracking, while it also touches on track calibration and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, CINEBOT_MINI, and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:00 — Intro
- 00:19 — Clear job & New
- 00:58 — Release brake on Track
- 02:08 — Take note – Track hard and soft limits
- 02:59 — Store positions – take note of camera path
- 05:25 — Amend move in Flair – Limits
- 08:40 — Target/Focus distance
- 09:58 — Focus follows sensor vs Focus follows target
- 10:39 — Adjusting speed and keyframes
- 12:38 — Browsing
- 13:30 — Save move & incremental saves
12. Cinebots Kinematic Do Nots
AI Summary
A quick video showing situations that may get you in trouble with your Cinebot because of kinematics.
For operators using this as a reference, the main focus is kinematics, move programming, spline behaviour, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:26 — to go file new. So, I'm going to move it to a position
- 01:16 — able to reach that same position. Another thing not to do is to move the
- 02:30 — trying to go up and then halfway through the move instantly try and
- 03:52 — it. Thinks there's some kind of problem. It looks pretty simple that move. Okay.
- 04:57 — >> Okay. And this time I'm going to use these controls to move around my target.
- 06:05 — And it's not happy about it. It's not a big move, but it's not happy about it
- 06:52 — curve around it. But you need to be
- 07:58 — to save some time. Okay, so this is my move.
13. Estimate Target
AI Summary
A short video covering a very useful feature in Flair called "Estimate Target".
For operators using this as a reference, the main focus is move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
14. Adjusting moves & keyframes using Push Moco and the Flair 7 interface

AI Summary
A video demonstrating how to adjust moves and keyframes using Push Moco and Flair 7.
For operators using this as a reference, the main focus is move programming, spline behaviour, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
15. Limits of the rig during Moves & Browsing
AI Summary
A video demonstrating rig limits during moves and handheld controller browsing.
For operators using this as a reference, the main focus is HHB, motion smoothing, move programming, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and HHB. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:15 — want to explain the difference between the handheld
- 01:15 — it can become dangerous doing it while moving it manually whereas in a move
- 02:12 — slowly creeping along very slowly just going to speed up a
- 03:01 — move and
- 03:54 — at round about there it turns blue indicating that it's going too fast it's
- 05:04 — positional limits this is my velocity limits and
- 06:12 — something is too fast uh it's important to heat it but
- 07:03 — potentially tip over so generally speaking whenever you run a move you
16. What is MRMC's Target Tracking and how to use it
AI Summary
A video explaining MRMC's Target Tracking and how to use it.
For operators using this as a reference, the main focus is CGI matching, Maya workflows, motion smoothing, move programming, and target tracking, while it also touches on track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:10 — something about uh what we call Target tracking Target tracking was developed
- 00:57 — nowadays in 3D uh uh programs and CGI
- 02:06 — and free Drive good so I have a simple two-point move if I look at it
- 02:58 — obvious uh so I'm going to adjust my move even further
- 05:08 — cm okay so what I do uh I'm at the end of my move so I'm going to type here
- 06:17 — have seen that my focus didn't adjust to my focus uh earlier when I ran the move
- 08:11 — roll is set to relative which it can't do when it's not in Target tracking so
- 08:57 — two target positions because each key frame or Waypoint has its own Target
- 10:29 — created a key frame yet I'm going to create now so add a new Waypoint way
- 11:17 — accelerating and this is effectively by this is 49% too fast or over
- 12:23 — okay so with regards to Target tracking you can always measure with a
17. How Kinematics relate Target Tracking
AI Summary
A video explaining what is the kinematics file in relation to target tracking in Flair.
For operators using this as a reference, the main focus is CGI matching, import/export, kinematics, move programming, and target tracking, while it also touches on zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:05 — in an earlier video we looked at a Target tracking move and we showed how
- 00:52 — roll moves then the move that we get
- 01:38 — that I'm going to turn on target tracking again I'm going to turn on Roll
- 02:27 — to so we're in the home position and
- 03:54 — and we can do that right the way through the move these axes of motion are
- 05:54 — that we need to do so this file is specific to the Target tracking axis if
- 06:41 — time or go on a remote location and shoot the same move again in order to
- 07:28 — position is with regard to the rest of the rig of otherwise the target tracking
18. Use of Carts, Master Axes and editing move timings
AI Summary
A video on the use of Carts, Master Axes and editing move timings in Flair 7.
For operators using this as a reference, the main focus is CGI matching, axis limits, move programming, spline behaviour, and target tracking, while it also touches on track calibration and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Both. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 21 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:07 — we have six axes in order to make this target tracking work but on this
- 00:53 — handle that in a specialized way if the track axis here were merely a Target
- 01:40 — tracking and if I want the camera to be
- 02:31 — where that is and set up my move so here I
- 04:07 — pull so I'm now in a position where I can if I wish move on to create my first
- 04:54 — there so while still in carian control I'm going to move my track
- 05:57 — close to camera pan being zero in I'm looking there I'm
- 06:45 — again I'm going to move back in x a
- 07:37 — view just to make sure it does actually run the track is doing its own thing
- 08:43 — to store a position there now I have a nice curve move in
- 10:17 — shoot okay so I have that move the
- 11:19 — extend the camera there back along the track as it happens I don't have much
- 12:08 — now and if I back run that yes I'm getting close to the limit
- 12:57 — that so now we have 150 frame move and that frame that
- 14:00 — there so I have actually changed the curve of
- 14:47 — that number just as well but that is giving me a more curve more of a curve
- 15:55 — nice nearly straight line there and a nice curve there and this is suitable to
- 16:41 — will not change the curve if I have a a
- 17:29 — by changing my move frame rate if I
- 18:21 — experiment so now it's now 100 frame move uh sorry it's now a 240 frame move
- 19:07 — takes place but it is exactly the same curve and those two curves on a
19. Focus modes in Flair 7
AI Summary
A video explaining the different Focus Modes in Flair 7.
For operators using this as a reference, the main focus is move programming and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 5 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:50 — you can measure it's an independent axis so it's not going to follow the
- 01:36 — Target situation and we can now look at this move I have a twoo move there I'm
- 02:22 — move if I want to do that I'm going to
- 04:35 — independent axis if that was a Target tracking axis if any of these other
- 06:09 — middle and my focus is an independent axis that is set to follow his object
20. Fairings - A Basic Explanation
AI Summary
A video explaining what are Fairings and how are they used.
For operators using this as a reference, the main focus is motion smoothing, move programming, pre/post-roll, spline behaviour, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes TURNTABLE. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:14 — confusion about them fairings also known as eases are the way that the curve
- 00:59 — the fairing here and there and apply it and it will adjust my curve or I can
- 01:47 — up with what is called a spline a spline
- 02:49 — now now if there is an actual change in Direction let's move this out the way
- 03:34 — section and decreasing in speed and if I
- 04:19 — I can force it to put a spline through
- 05:13 — stop because it's changing direction it never if you run the move never quite
- 06:03 — percentages to zero so if I change that to zero and
- 06:51 — starts at frame zero before frame zero
- 07:37 — one okay you'll see effectively my velocity my speed is constant throughout
- 08:30 — you'll see here it'll say pre-rolling when it's at frame zero then it'll run
21. Fairings Axis & Cartesian
AI Summary
A video explaining the Fairings Axis and Cartesian in Flair 7.
For operators using this as a reference, the main focus is motion smoothing, move programming, pre/post-roll, spline behaviour, and target tracking, while it also touches on track calibration and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK and TURNTABLE, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 13 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:12 — fairings also known as eases or ease in and ease out um but I've got a move
- 01:10 — there are only two key frames or there is a change in Direction then the spline
- 02:06 — the cartisian fairings these are to do with Target tracking axes so if we look
- 03:10 — frames you have a an acceleration okay so here for 23% of
- 04:24 — almost a corner here because it approaches this with a constant speed
- 05:11 — see that there is a very Sudden Change in speed for most of the axes then a
- 05:57 — Waypoint so in my cartisian Waypoint I
- 07:26 — the in the fairings menu is there is something called Curve reversal
- 08:49 — and then it overshoots it goes beyond it it will look nice and smooth but it may
- 09:36 — okay that's the point of curve reversal
- 10:37 — to start off with a simple two-point move so for example if I remove my
- 11:26 — apply you'll see this Curve will
- 12:17 — okay and shoot does a little pre-roll
22. The Four Main Cartesian Control Modes
AI Summary
A video covering the four main Cartesian Control Modes in Flair 7.
For operators using this as a reference, the main focus is motion smoothing, move programming, target tracking, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:11 — in order to be able to do correct Target tracking this particular rig amongst the
- 01:05 — motion if you look at this it has Target tracking it's a Target tracking type
- 01:53 — locked level or relative in in order to do the target tracking it is called a
- 02:39 — tracking is a capability to move around
- 03:59 — Zed and the world cartisian is a universe that is aligned with the rail
- 04:46 — in y my camera moves in a straight line across the rail he's moving in a
- 05:33 — the rail so the camera is moving
- 07:58 — world the camera and Target are locked together so if I move in
- 08:54 — the two are staying in parallel to the rail if I move in Zed again the camera
- 11:03 — in locked View and my target is going to move with the camera because they are
- 12:30 — common uh systems for finding way points in order to do normal Target tracking
23. Axis vs Cartesian Priority
AI Summary
A video explaining the difference between Axis Priority and Cartesian Priority in Flair.
For operators using this as a reference, the main focus is move programming, target tracking, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:16 — fully understand it. Flare when you create a move stores the
- 01:01 — track is because the track is what we
- 01:47 — Okay. But my track if I move it
- 02:34 — adjust the move. But if I just adjust it
- 03:25 — >> okay, and now I go into cartisian control and adjust my track.
- 04:12 — Now if I now adjust one of these, let's say I move my lift up for whatever
- 05:19 — convert these back into axes using this new track value.
- 06:49 — So this is my move.
24. Different Roll Modes
AI Summary
A video describing the different roll modesin Flair.
For operators using this as a reference, the main focus is EtherCAT, Maya workflows, import/export, move programming, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
25. Animation, Timelapse & Part Runs
AI Summary
A short video describing the Animation, Timelaps & Part Run options in Flair 7.
For operators using this as a reference, the main focus is HHB, move programming, pre/post-roll, synchronization, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
26. Output & Input Triggers & the Bloop Light

AI Summary
A short video demonstrating how to use Output Triggers, Input Triggers and the Bloop Light with a Cinebot Mini.
For operators using this as a reference, the main focus is firmware flashing, move programming, synchronization, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BLOOP_LIGHT, CINEBOT_MINI, and TRIGGER_BOX. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
27. Profiles in Flair
AI Summary
A video covering how to manage different profiles in Flair.
For operators using this as a reference, the main focus is HHB, hot booting, import/export, and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and the working environment is Flair Classic. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:43 — could then set hit set active and flare will restart into that profile. Uh and
- 01:29 — By reverse, if you want to import a profile, you use
- 02:17 — for flare bridge. If you want to overwrite and import the HHB
- 04:19 — versions of Flare, maybe different rig models, and move them to other devices
28. Explaining the 3D Rig model display in Flair 7
AI Summary
A video explaining the 3D Rig model display in Flair 7 and how to use it.
For operators using this as a reference, the main focus is Phantom workflows, import/export, move programming, robot safety, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_PHANTOM and CAMERA_RED, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 9 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:15 — have a 3D model of your rig your move and lots of additional information
- 01:06 — Backwards I can pause it carry on okay I can also make it just repeat
- 03:19 — a line all the way through the move of what the camera is doing
- 04:42 — view okay next we can import 3D rig models I have one here
- 05:50 — is so let's say I want to be 2 m to the side of my rail minus 2
- 06:43 — what you can also do is you can also move the model on the screen
- 08:00 — those older members of the public amongst us and then there's a Phantom
- 09:06 — this is what it looks like from the top and this is my move from the
- 09:52 — is what it's going to see as I run that move so you can actually simulate moves
29. RED Komodo & Raptor Syncing
AI Summary
A short video showing how to connect the RED Komodo (or V-Raptor) and the Raptor XL to Flair.
For operators using this as a reference, the main focus is Network Direct, Phantom workflows, move programming, and synchronization. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, CAMERA_PHANTOM, and CAMERA_RED, and software/version references include Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
30. The Waypoint View in Flair 7 explained
AI Summary
A video explaining the Waypoint View in Flair 7.
For operators using this as a reference, the main focus is motion smoothing, move programming, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, CINEBOT_MINI, PRECISION_TRACK, and TURNTABLE, and software/version references include Flair 7, and the working environment is Both. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 26 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:08 — okay so I'm going to run through the Waypoint display here I make it full
- 01:26 — store and then add a point and move it
- 02:24 — okay these are the shortcut buttons so this is delete Waypoint and this is to
- 05:34 — can use this slider okay this here allows you to move the axis it's like a
- 06:20 — move side to
- 07:07 — down speed up a bit more speed up a bit
- 07:57 — run uh once I unlock it it's then free to move okay
- 08:45 — position it just goes to it it'll take my rotate to zero or I can tell it to go
- 09:48 — here on the rotate uh go to home I can access from
- 11:41 — okay uh as I said the menu changes so for example the track axis has different
- 12:41 — region which you can set where that region is but effectively as I move it
- 13:36 — checkboxes are whether the axis is on or off so for example my track is off at
- 14:58 — very useful unless you want to make sure nobody Chang es anything or doesn't move
- 16:28 — to note that whenever you use these buttons here to move the rig these this
- 17:23 — sensible so now if I go into my cartisian mode to move the camera around
- 18:19 — tilt pan doesn't pan all the axes are at strange angles and when you try and move
- 19:10 — before I do that I'm going to go to this Waypoint view
- 20:12 — well um then we've got show Waypoint images
- 21:02 — to say that you know this is uh this is the Waypoint where the actor enters
- 23:53 — buttons uh effectively as we did in the vertical Waypoint display except for
- 24:55 — to copy waypoints if I want to copy uh Waypoint one to here I just type in one
- 26:12 — waypoints so the same Waypoint menu as
- 27:28 — going to that was just going to start that wasn't the actual move uh but my
- 28:26 — priority to cartisian axis that means it will run the move that's here rather
- 29:46 — it because I'm at the end it'll go 5 cm down but then during the move it'll
- 30:39 — so forward run starts 5 cm high and then during the move goes 5 cm
31. The Runtime/Timeline display in Flair 7
AI Summary
A video covering the Runtime/Timeline display in Flair 7.
For operators using this as a reference, the main focus is CGI matching, HHB, motion smoothing, move programming, and pre/post-roll, while it also touches on synchronization and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and HHB, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 19 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:28 — go full screen here on the key on the key frame display or Waypoint display
- 02:12 — button you have may have programmed onto your handheld controller Gamepad or
- 03:51 — on so now I can it's controlled and let's I'll move it to
- 04:44 — frame okay you can even adjust the timing so you can drag this Waypoint
- 05:48 — you do a part run the move between frame 30 and frame
- 07:03 — okay and you will see there will be a small pre-roll and then a slightly
- 07:49 — zero and frame 150 I just press that and
- 09:16 — actually browse which I'll show you in a minute uh or run the move okay so
- 10:12 — browse you either just forward run to go into running the move or you just press
- 11:00 — so I've reached the end of my move
- 12:00 — your camera back on ready for the next take okay if you don't like the speed
- 12:47 — because I can take one step forward okay and if I do that it'll move one frame
- 14:59 — button each time it'll do a pre-roll and a post
- 16:06 — not going over position but it is going too fast over velocity and is going over
- 17:04 — okay these buttons here will affect the move either by slowing it down to 22
- 18:20 — slide uh or shift and that means that your passes will no longer match your
- 19:10 — speed okay last then next we have the
- 20:12 — that the exposure will happen exactly the same place in every move it's very
- 21:06 — do with a move okay next we have the
32. Live View Display in Flair 7 & Focus Assist
AI Summary
A video covering the Live Vew display in Flair 7 and also the Focus Assist module.
For operators using this as a reference, the main focus is HHB, move programming, target tracking, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 12 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 01:23 — set just leave it at device zero
- 02:30 — just to explain these buttons here move the camera in
- 03:23 — axis okay if I just take it back to my start position of my move that I had
- 04:22 — doing okay this one will move in an arc
- 05:29 — just adjusts that because it knows where my target is based on the Move I've
- 06:36 — use my rotate to move my individual axis so now
- 09:17 — axis and right click I have this option here Focus follow
- 11:29 — position it'll also at that whenever I click on it also move the focus to that
- 12:52 — okay here is my move okay and you can see the background
- 13:52 — does give you a good indication of what the move is going to be so if you have a
- 14:46 — iPhone the address of where to get this video feed from so that as you move the
- 17:33 — going to make it larger so that's how I move it around
33. Keyboard & Mouse shortcuts in Flair 7
AI Summary
A video showing the many keyboard & mouse shortcuts that are available.
For operators using this as a reference, the main focus is HHB and move programming. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 10 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
34. File Menu & CGI Import/Export
AI Summary
A video explaining the File menu of Flair 7 and the many options when exporting and importing moves.
For operators using this as a reference, the main focus is CGI matching, EtherCAT, Maya workflows, axis limits, and hot booting, while it also touches on import/export, mimic systems, move programming, spline behaviour, and synchronization. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BLOOP_LIGHT, MIMIC, PRECISION_TRACK, and TURNTABLE, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 7 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
- 00:00 — Intro
- 00:13 — New, Reset All & Save – how changes to settings are saved and recalled
- 04:00 — Job Storage, Recent Jobs & Load Simple Job
- 05:43 — Reload Current Job, Append Job, Merge Job
- 09:38 — Exporting a Move & options
- 16:43 — Importing a Move & options
- 26:13 — Exporting & Importing Configuration data
35. Help Menu in Flair 7
AI Summary
A video explaining the Help Menu in Flair 7 including how to send a software bug report and license request.
For operators using this as a reference, the main focus is move programming and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
36. Handheld Controller Setup in Flair 7
AI Summary
A short video explaining how to set up a wired hand controller (HHB) such as a game controller.
For operators using this as a reference, the main focus is HHB, move programming, robot safety, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes HHB, and software/version references include Flair 5 and Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
37. Goto Menu & Goto Browsing
AI Summary
A video describing the Goto Menu options in Flair 7.
For operators using this as a reference, the main focus is move programming, pre/post-roll, track calibration, and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 11 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
38. Adding a Network Node in Flair
AI Summary
Adding a network node in Flair including.
For operators using this as a reference, the main focus is EtherCAT, Network Direct, firmware flashing, hot booting, and import/export, while it also touches on move programming, synchronization, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes BOLT, BOLT_JR, PRECISION_TRACK, TRIGGER_BOX, and TURNTABLE. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 9 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
39. Self Mimic on Cinebot

AI Summary
A video showing how to use Self Mimic on the Cinebot Mini in Flair 7.
For operators using this as a reference, the main focus is mimic systems, motion smoothing, move programming, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CINEBOT_MINI, MIMIC, and PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 4 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
40. Connecting RED Camera Settings to Flair 7
AI Summary
A short video demonstrating how to connect your RED camera to Flair using RCP.
For operators using this as a reference, the main focus is Network Direct. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, and software/version references include Flair 5 and Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
41. Tracker App Setup (Windows)
AI Summary
This tutorial shows the complete Windows network setup needed to use an iPad running the MRMC Tracker App as a live controller for a robot in Flair. It explains why the real-time InTime-controlled robot network must be bridged to a Windows network connection and recommends using a small dedicated Wi-Fi router instead of a busy studio or office network. The configuration walkthrough covers enabling the InTime network bridge, assigning the Windows adapter a static IP address, editing netuser.cfg, and configuring a GL.iNet smart router with compatible LAN and Wi-Fi settings. It then connects the iPad to that wireless network and enters the Flair computer's IP address in the Tracker App. The final section opens the Tracker interface in Flair, selects the appropriate camera and scaling options, enables Mimic mode, and demonstrates the robot responding to movement of the iPad. Operators can use the chapter links to jump directly to the InTime, Windows, router, iPad, or Flair portion of the setup.
For operators using this as a reference, the main focus is Tracker App setup, Windows networking, and live control, while it also touches on InTime bridge configuration, static IP addressing, and Wi-Fi router setup. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes iPad, Cinebot Mini, and GL.iNet smart router, and software/version references include Flair Classic and InTime, and the working environment is Flair Classic on Windows. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 7 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
42. Tracker App Setup (Linux)
AI Summary
A video showing how to set up the iOS Tracker App with Flair 7 running in Linux.
For operators using this as a reference, the main focus is Network Direct, axis limits, move programming, target tracking, and track calibration. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes PRECISION_TRACK, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
43. Tracker App Live Control
AI Summary
A video covering the options to live control the robot through the tracker app.
For operators using this as a reference, the main focus is mimic systems, move programming, robot safety, and target tracking. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED and MIMIC. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
44. Tracker App - Record Vision
AI Summary
A video showing the "Record Vision" option of the iOS tracker app.
For operators using this as a reference, the main focus is import/export, mimic systems, move programming, target tracking, and track calibration, while it also touches on zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes CAMERA_RED, MIMIC, and PRECISION_TRACK. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 6 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
45. Flair on Linux - An Overview

AI Summary
A short introduction into Flair 7 running on Linux and highlighting some of the key changes to a windows environment.
For operators using this as a reference, the main focus is EtherCAT, Network Direct, firmware flashing, import/export, and move programming, while it also touches on target tracking and zeroing. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that software/version references include Flair 7, and the working environment is Both. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 8 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters
46. Flair 7 on Linux - Overview Part 2

AI Summary
A video covering how to back up Flair settings in Linux and how to perform a Flair software update.
For operators using this as a reference, the main focus is hot booting and import/export. It should help when deciding which Flair workflow, robot behaviour, or setup area is relevant before opening the full video.
The practical setup context is that hardware referenced includes TURNTABLE, and software/version references include Flair 7, and the working environment is Flair 7. This helps connect the video to the rig, accessory, software environment, or workflow label an operator may already be working with.
The chapter links below provide 3 timestamped jumps into the main setup, demonstration, and workflow moments, making it easier to go straight to the section that matches the issue or task being investigated.
Chapters